A robot is rarely the hard part. The hard parts are the end effector, the part presentation, and the safety case. We integrate robotic cells into lines that already exist, which means working within your cycle time, your footprint and your existing controls.
Capabilities
Collaborative Robots
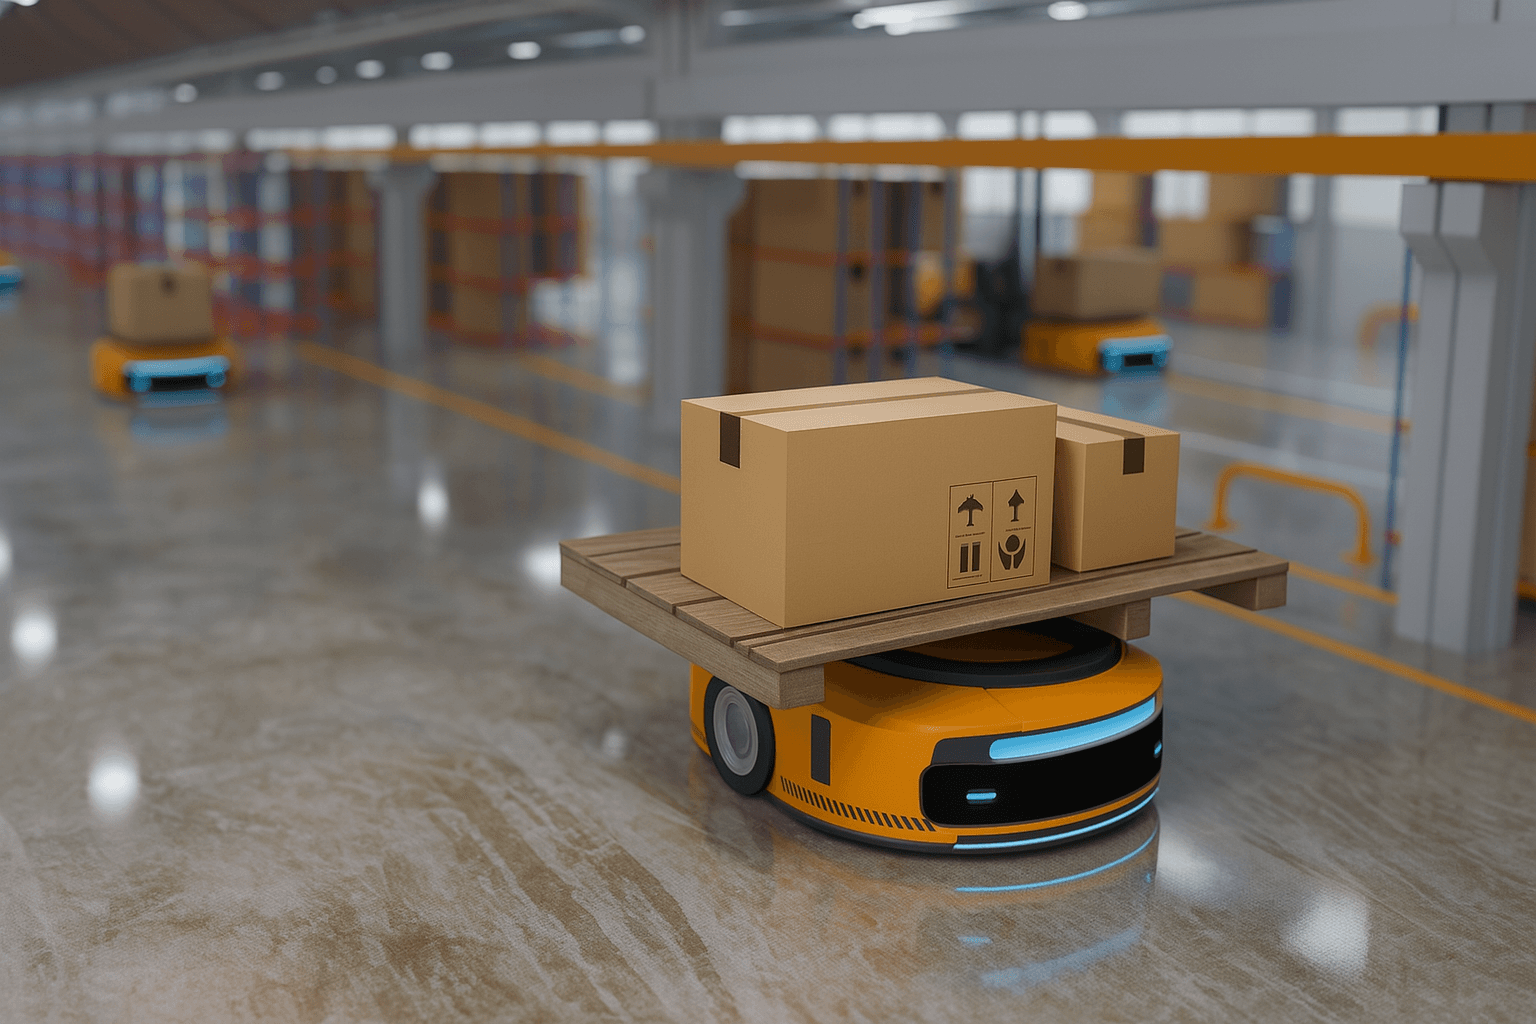
Warehouse Robots
Custom End Effectors
Safety Systems
Path Planning
Multi-Robot Coordination
How we deliver it
Cycle time modelling
We establish whether the cell can actually hit your rate before any hardware is committed.
End effector design
Gripping and tooling designed around your part, which is usually what determines success.
Vision guidance
Where parts are not fixtured, vision provides position so the robot can find them.
Safety integration
Guarding, interlocks and risk assessment handled as part of the build, not afterwards.
When this is the right fit
Repetitive handling that is limiting throughput or causing injury risk
Pick and place where part position varies and fixturing is impractical
Palletising with mixed case patterns